7/8

Application to configure and control a robotic arm

Kinova

Redesigned how users configure and control Kinova's robotic arm, prioritizing key tasks to support use cases from assistive technology to industrial applications.

Challenge

Kinova needed an easier way to configure and control its robotic arm while supporting a broad range of use cases, from assistive technology to industrial applications.

My contribution

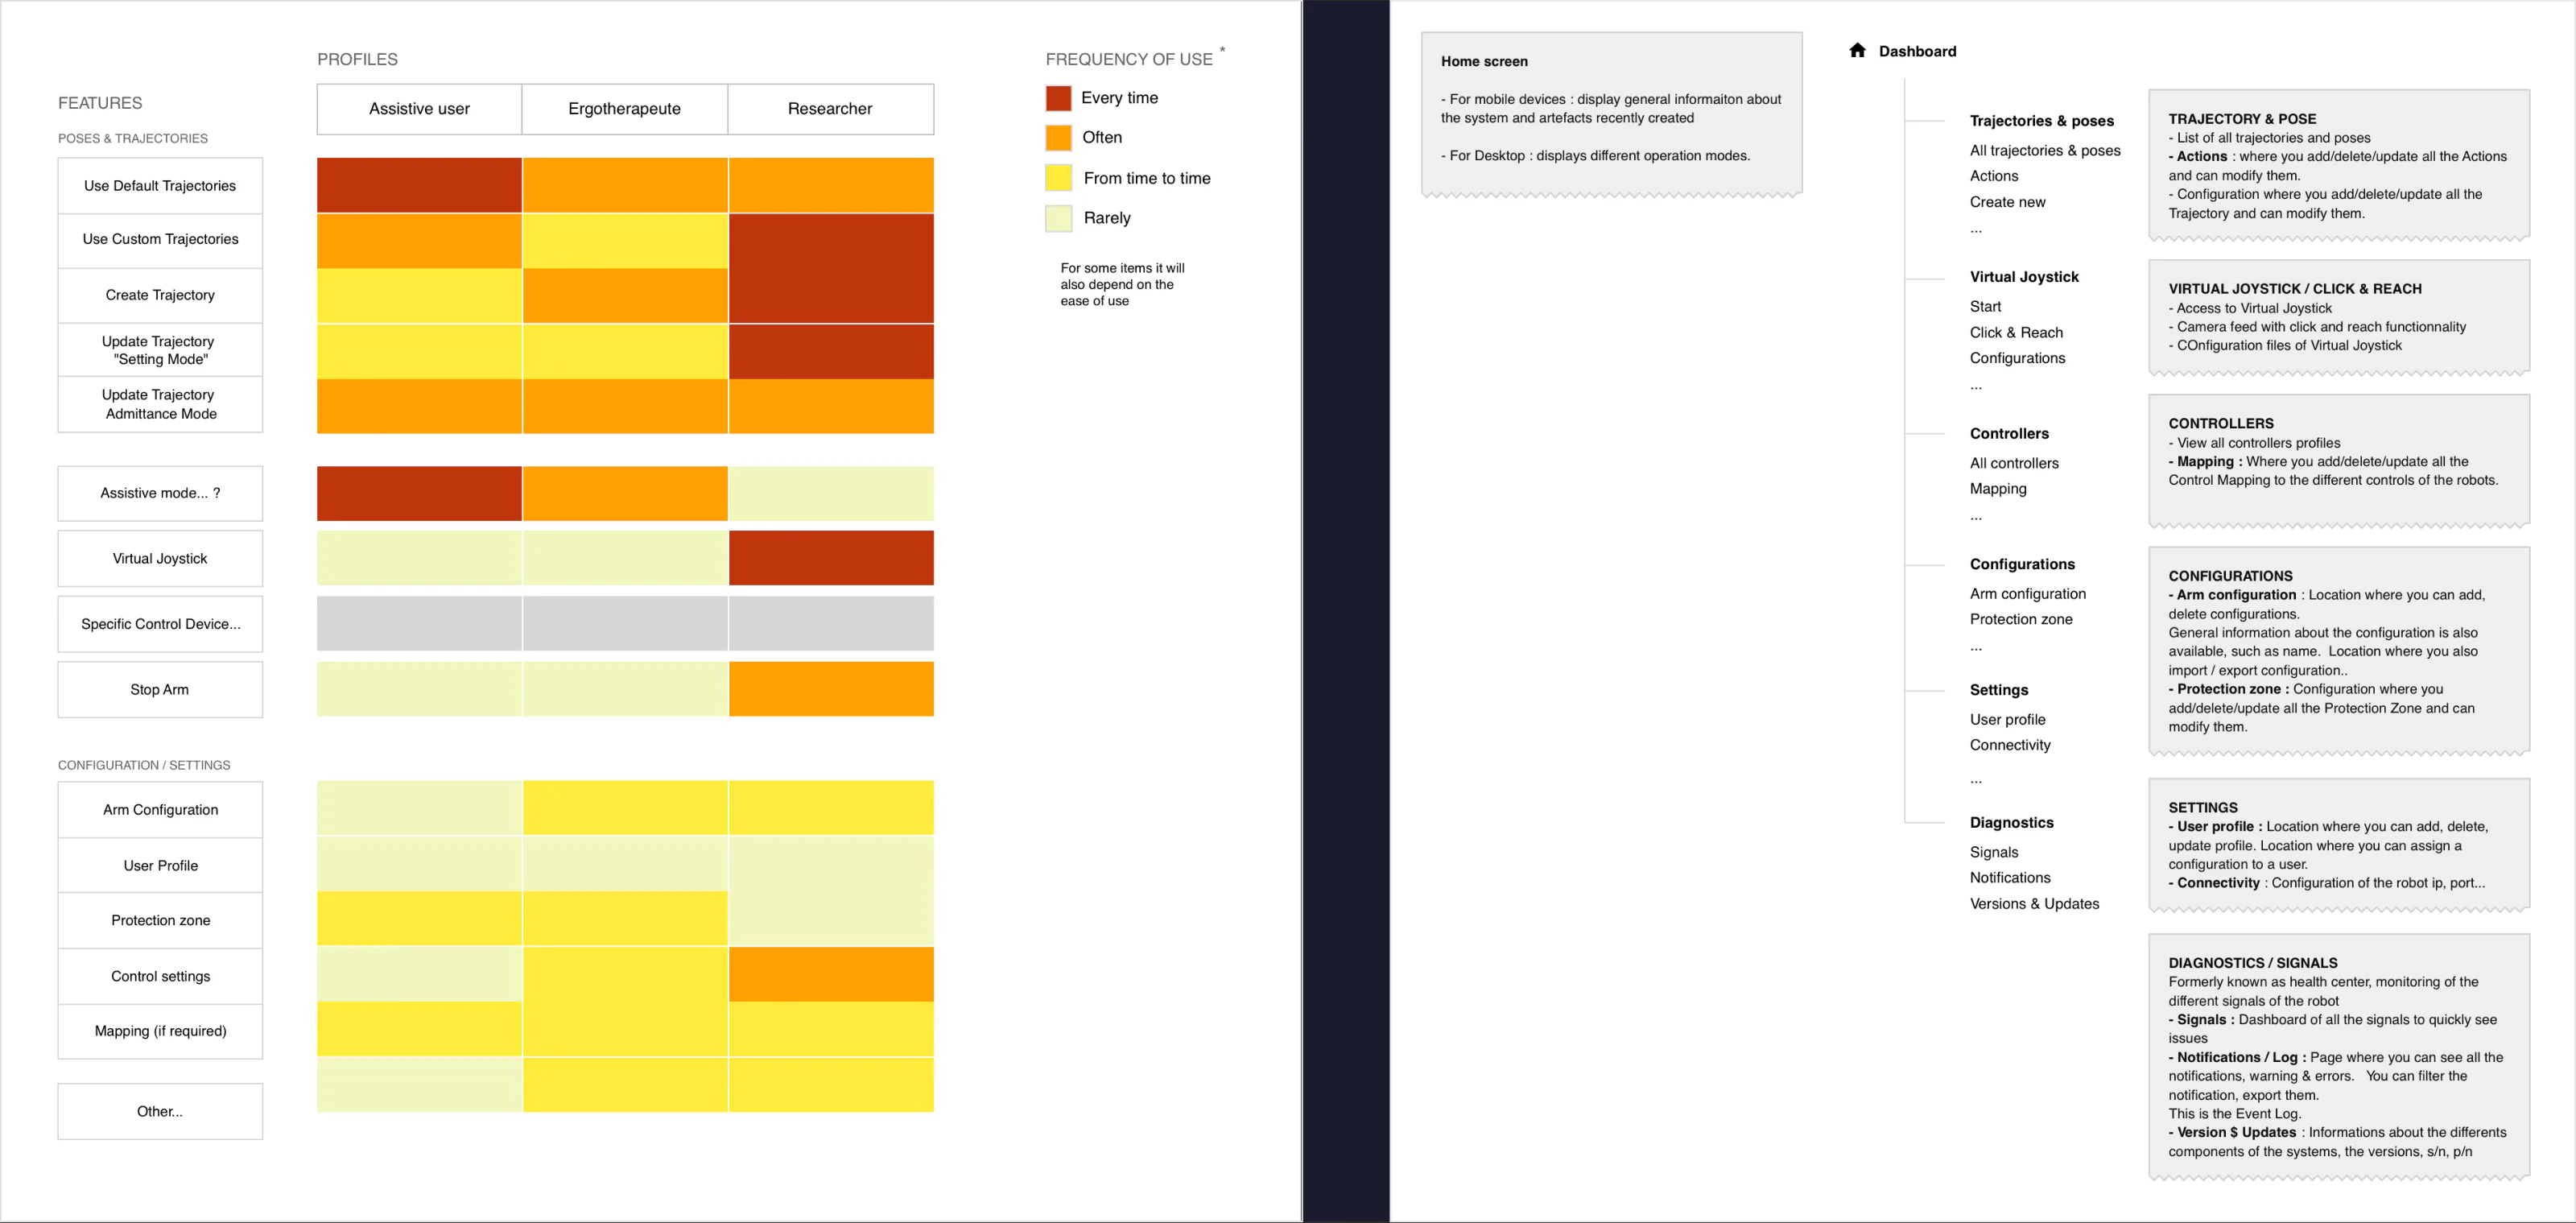
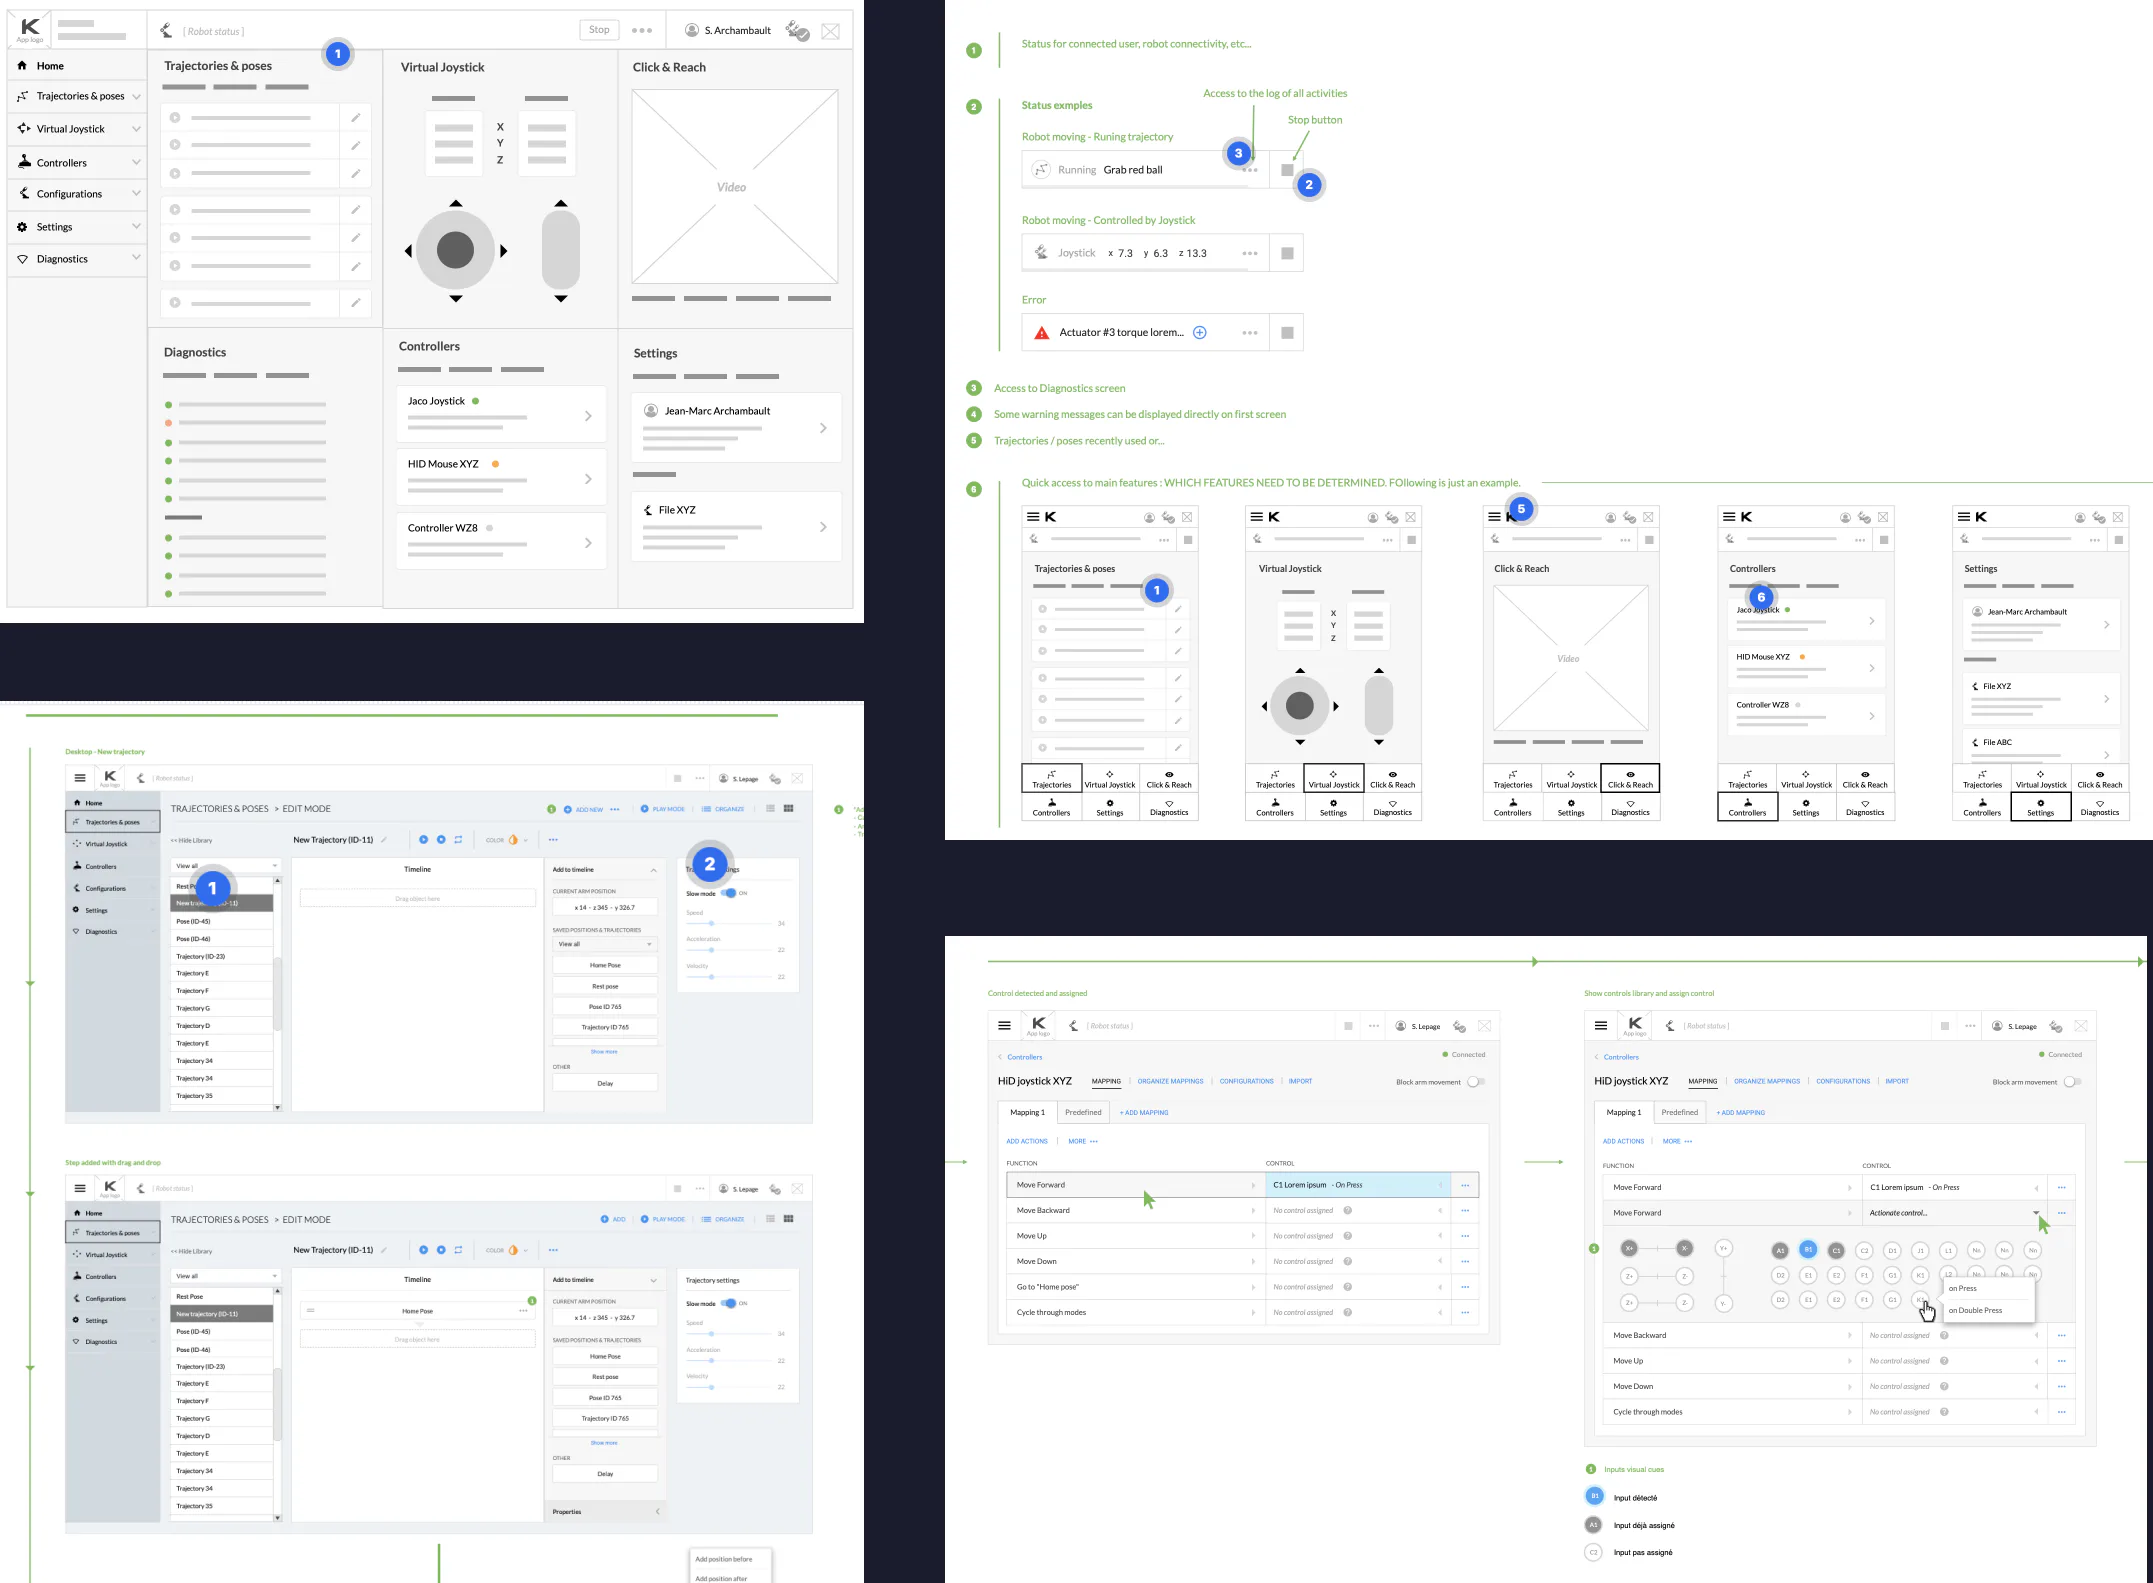
I prioritized features using the Top Tasks method, then created high-level wireframes to align stakeholders on the product vision and structure. I subsequently designed the interfaces in close collaboration with the Agile development team.

Results

The web application and new development platform made the robotic arm easier to use across a wider range of applications.

Identifying UX priorities and information architecture
Wireframe examples used to validate the concepts with stakeholders and the team
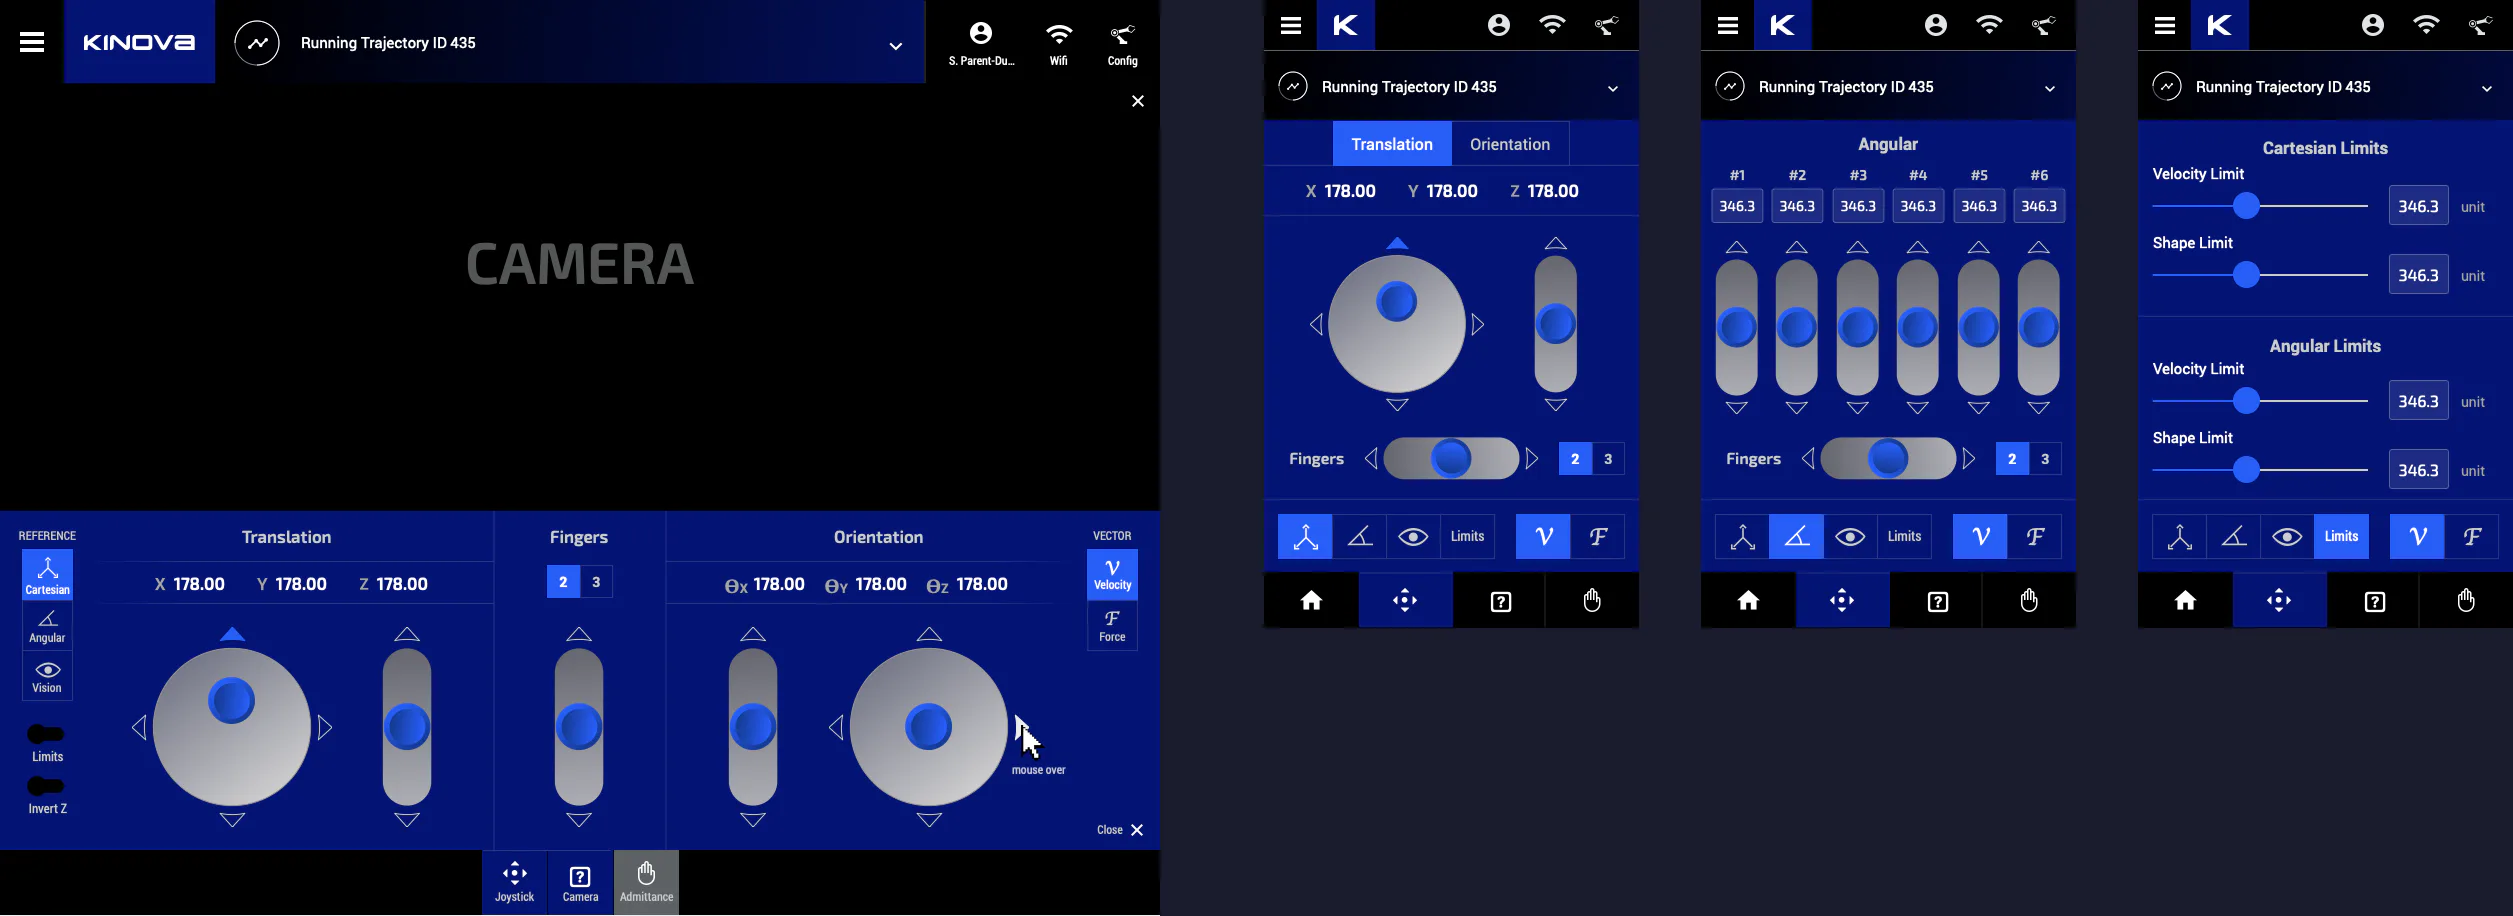
Detailed design: Joystick control
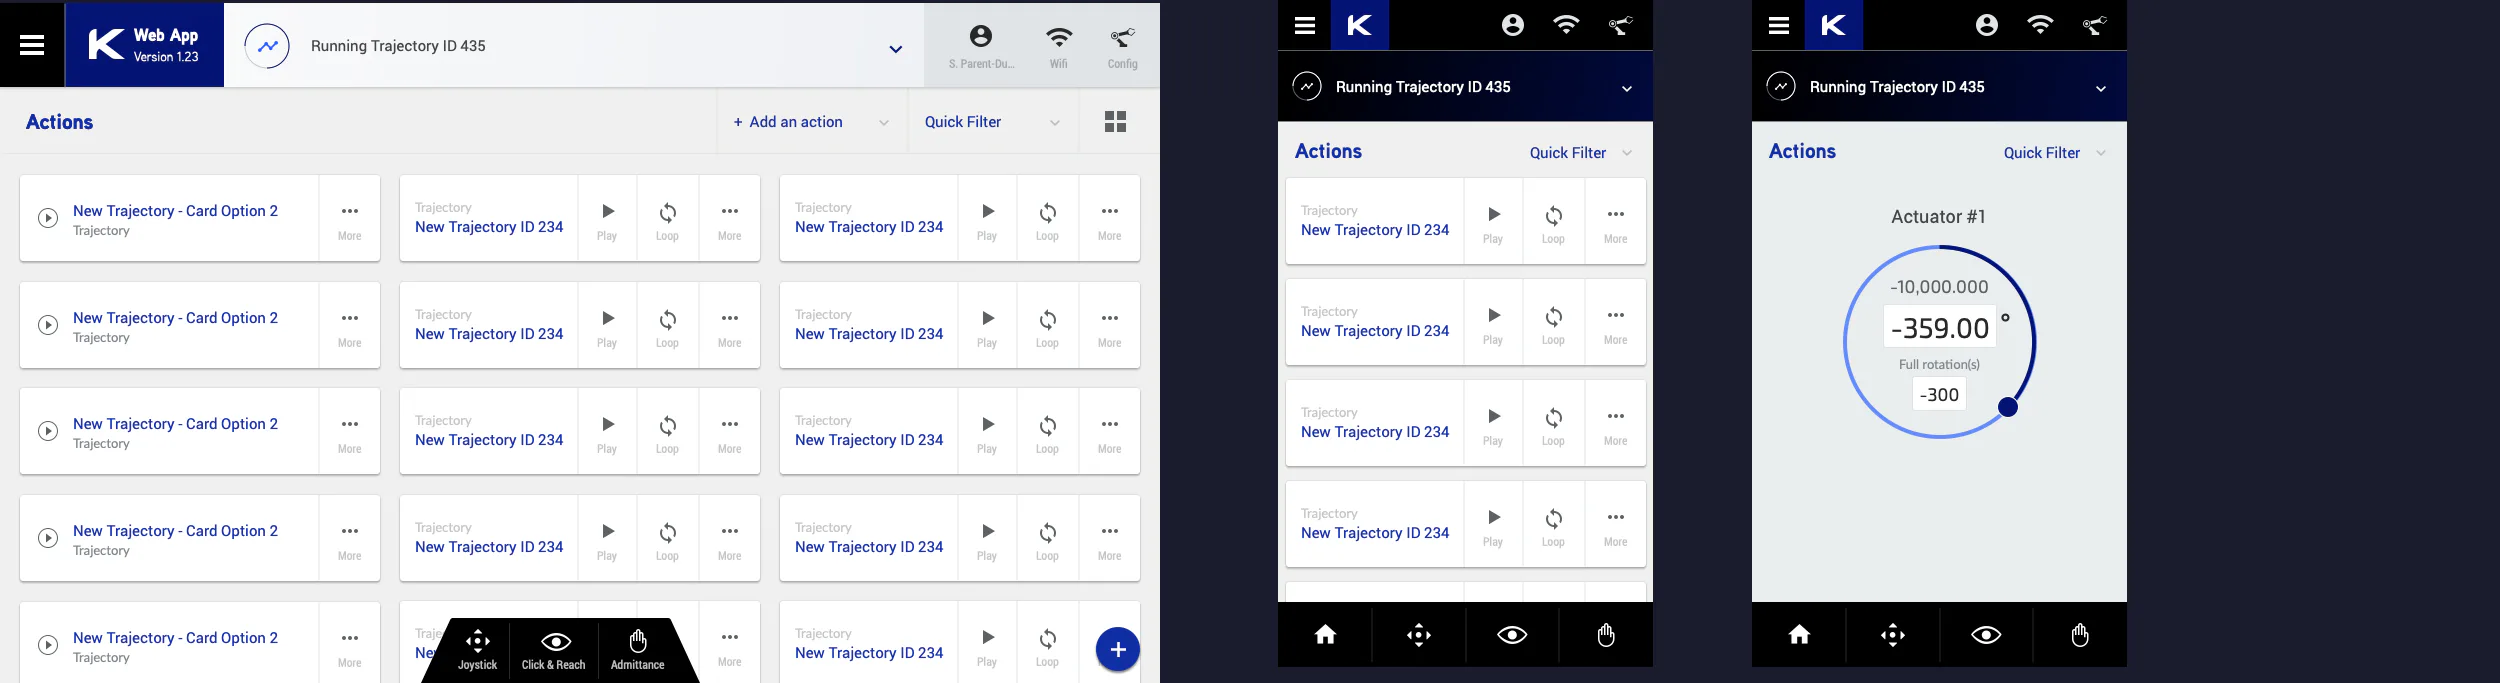
Detailed design: Actions library
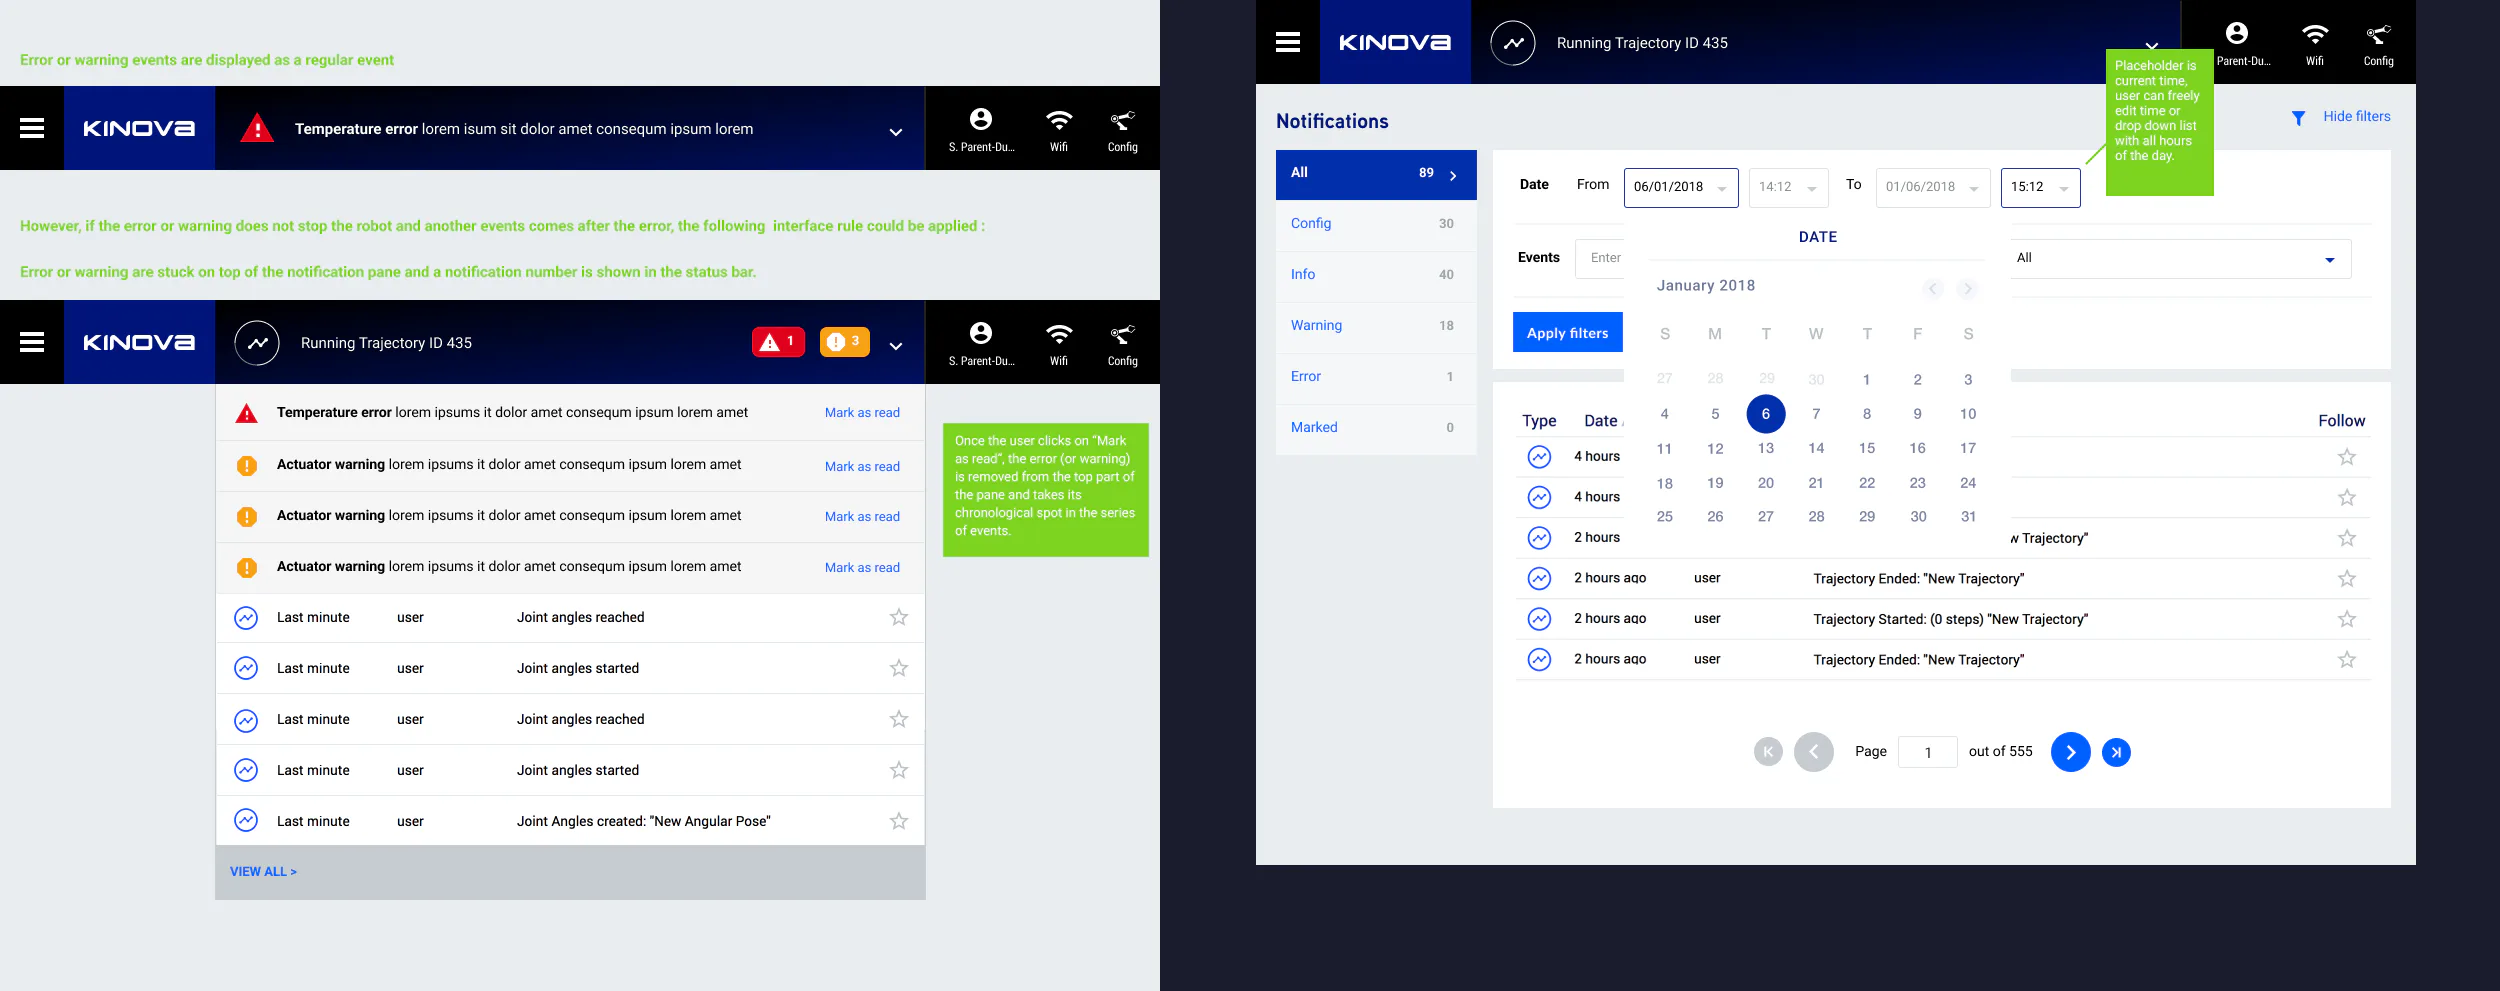
Detailed design: Notification center
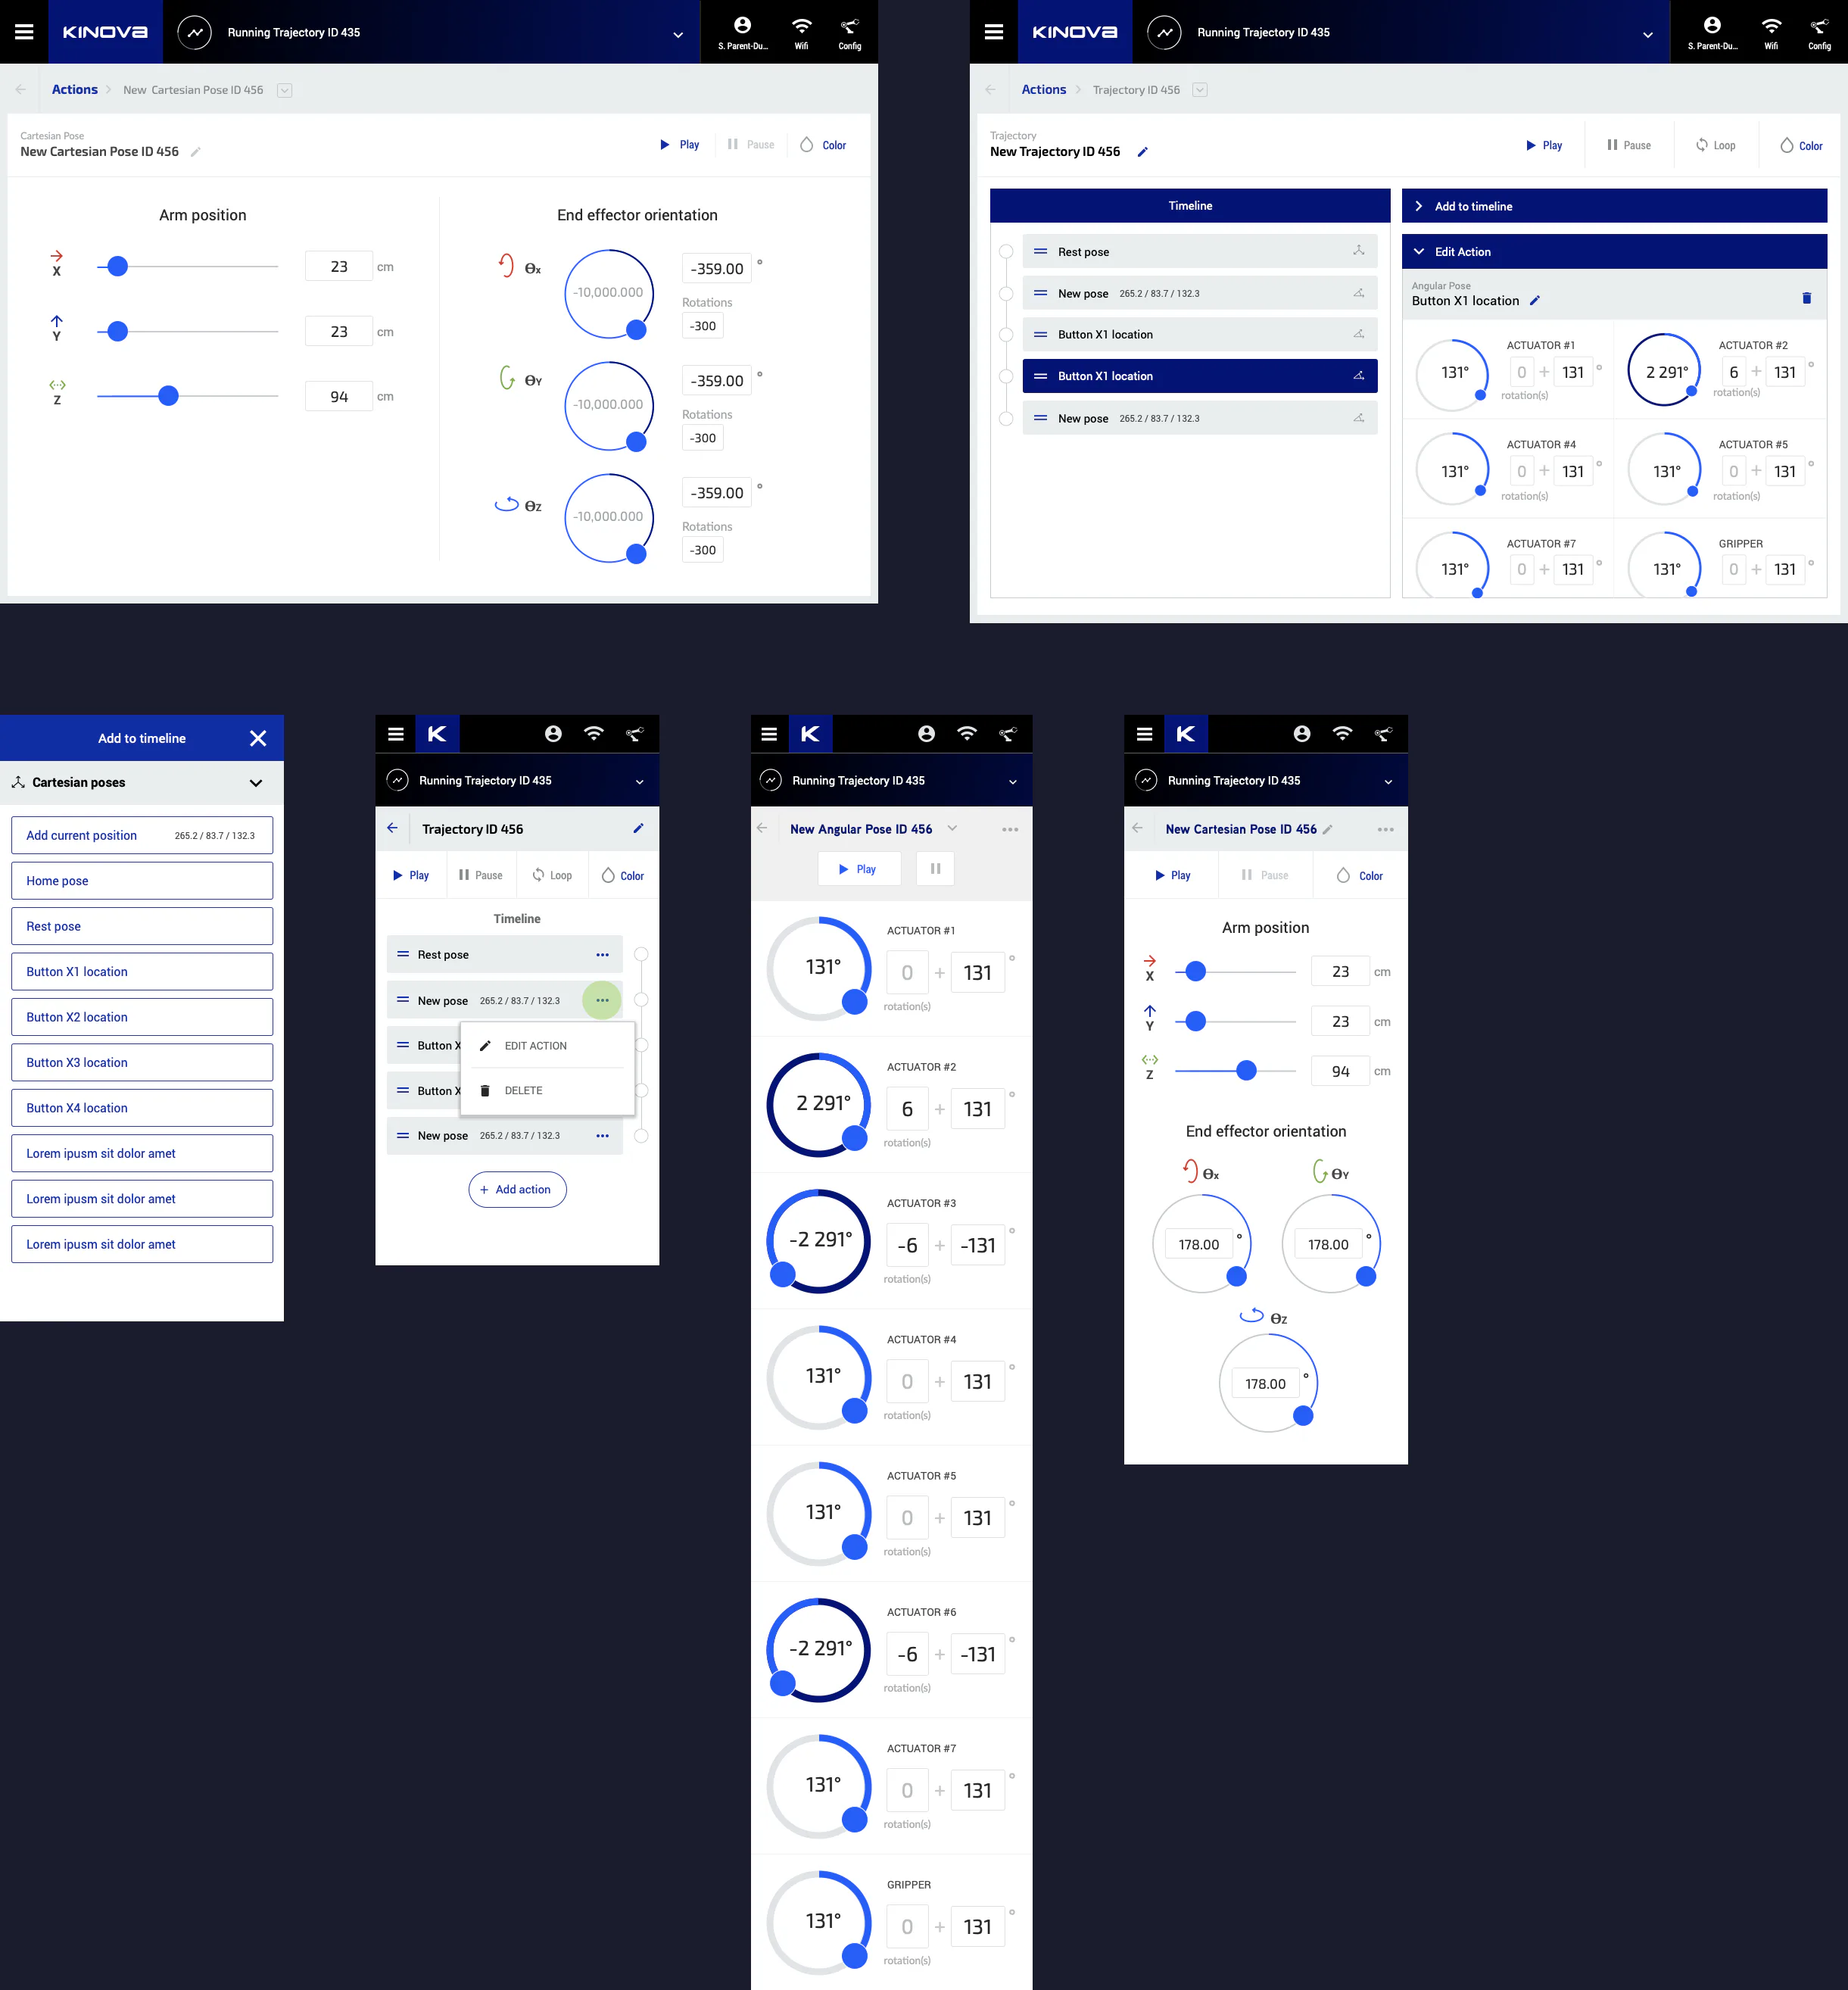
Detailed design: Building poses and trajectories